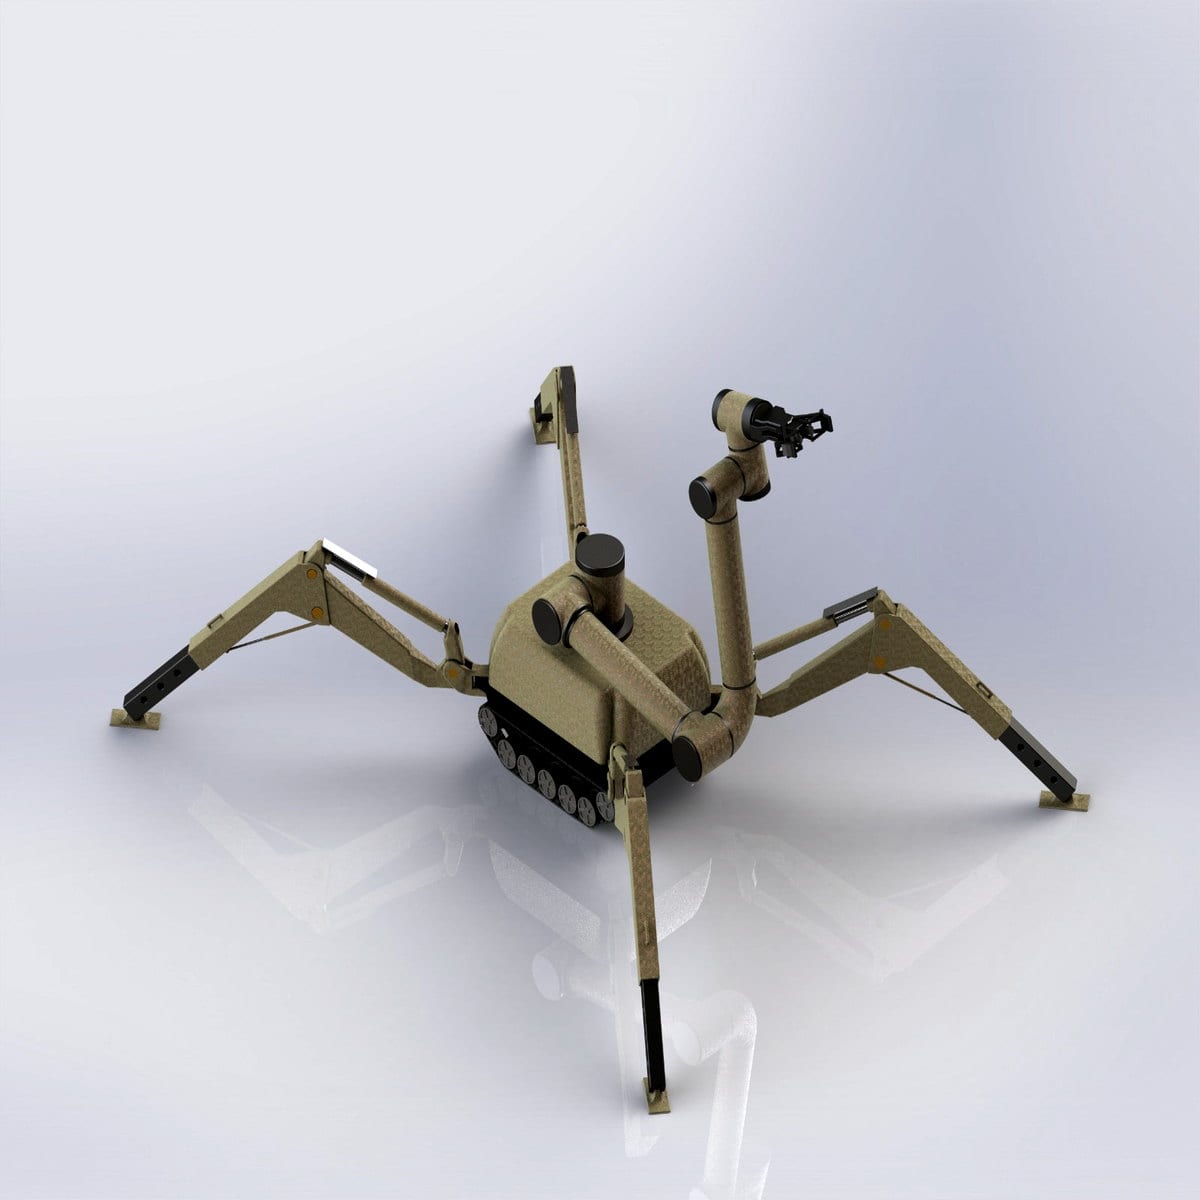
Multi-terrain robotic platform
Walking legs plus a caterpillar track, with modular payload mounts.
02Approach
Legs and track were designed as separate modules on a common chassis, so each could be tested and revised on its own. Leg geometry was worked through for stride, ground clearance and folded footprint, then the payload rail was standardised across the top deck.
03Result
A complete mechanical assembly with drawings and a bill of materials, split into modules that can be built and iterated independently.